
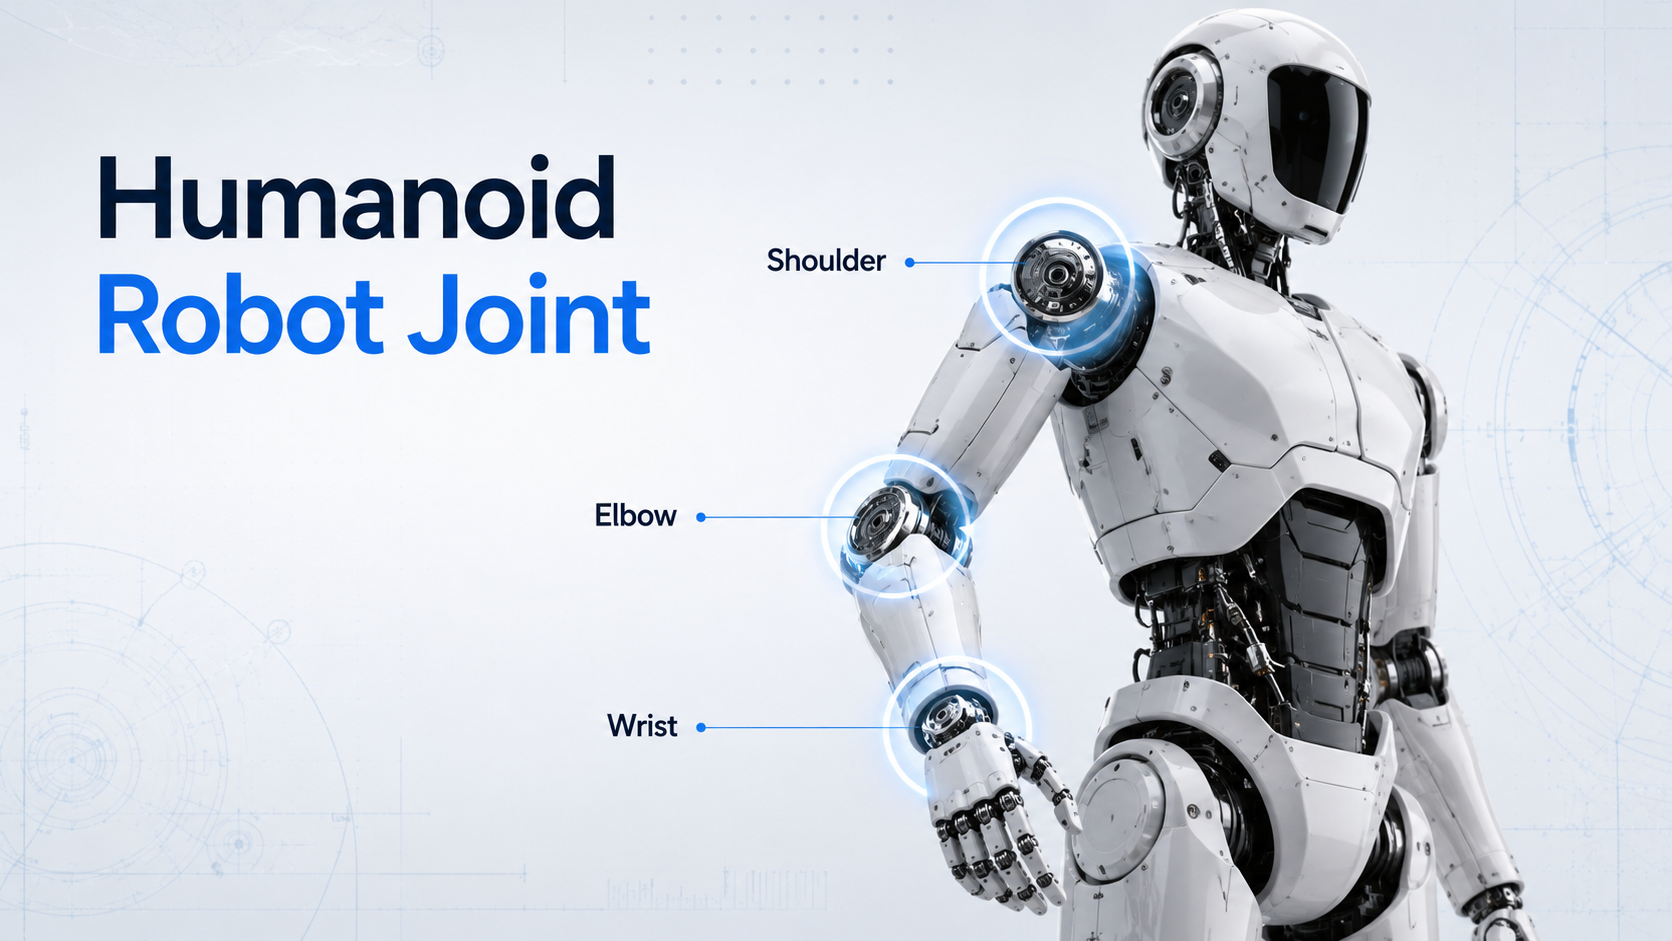
A joint is basically thought of as a rotating component, but there is a robot motor, reducer, encoder, and driver inside it. Joints must produce force, monitor the position, and operate efficiently in a small space. Whether a robot is able to lift its hand, grab anything or maintain its position becomes crucial depending on this component.
A typical humanoid robot usually needs 20 to 40 joints across the body. Each position has a different job. The shoulder has to carry the whole arm. The elbow has to keep the motion connected. The wrist has to handle the fine work at the end of the arm.
So let’s break it down by shoulder, elbow, and wrist, and look at why humanoid robots cannot rely on one motor setup for every joint.
Shoulder Joint Motor: The Load-Bearing Point of the Arm
The shoulder is the most demanding position. It carries the weight of the entire arm and also handles extra external loads during actions such as pushing, lifting, and carrying. Once the robot enters a real application scenario, the shoulder is no longer just a rotating joint. It becomes a power support point that must keep producing force.
In structural design, this is usually the heaviest part of the arm. It requires high torque, low speed, and long-term operating stability. The reduction ratio is usually higher, and the joint also needs stronger structural rigidity. Power-off protection is also critical. Once control is lost, the entire arm may drop, creating a major impact on the structure.
A pushing cart scenario makes this easier to understand. After the robot grips the handle with both hands, the shoulder joints are constantly resisting force. This is not a simple lift-and-lower motion. The torque changes continuously, which places high demands on control stability.
If the shoulder joint motor is not fully designed around real load conditions, and too much safety margin is left unused, it will directly limit the arm’s motion capability and performance ceiling.
Elbow Joint: Force Transmission and Posture Switching
The elbow rarely handles extreme tasks. Its main job is to connect movements and switch postures up and down or forward and back. It has to keep up with speed while maintaining control.
The force transmitted from the shoulder to the wrist passes through the elbow first. Its condition directly determines whether the whole arm moves smoothly or feels disconnected.
Motor selection for this position has no obvious single priority. Torque cannot be too low, or the motion will lack support. It also cannot be too high, or the robot’s overall weight and inertia will increase, slowing down response. The real difficulty is balancing speed, force, and control accuracy at the same time.
In actual structures, elbow joints often use solutions such as harmonic reducers to reduce size while maintaining stable output. Many designs also add dual-encoder feedback, with one encoder on the motor side and another on the output side, improving the predictability of control.
If this position is poorly balanced, the problem may not appear immediately. Over time, it can show up as motion delay, uneven trajectories, or poor coordination across the entire arm.
Wrist Joint: The Amplifier of End-Effector Motion
The wrist sits at the end of the robotic arm. It has the least space and handles the finest movements. It is responsible for actions such as grasping, rotating, and micro-adjustment. The space is small, the movement frequency is high, and the joint is very sensitive to weight and response speed.
Once motor weight increases, the impact does not stay at the wrist. It is amplified through the elbow and shoulder, increasing the inertia of the entire arm. The arm becomes slower, and control becomes harder to maintain.
The design logic for the wrist is straightforward: light, fast, and precise come first. Torque is not the top priority. It only needs to cover the basic load. Response speed and repeat positioning accuracy matter more.
Structurally, this section usually tries to compress volume while improving integration. Some designs consider sensors, wiring, and even the end effector together to make better use of limited space. Hollow structures and miniaturized motors are common here.
Recommended Joint Motors for Humanoid Robots
When applying the logic above to real motor selection, the core idea is simple: match power specifications by joint layer. This layered approach is essentially an engineering division based on three variables: torque demand, inertia constraints, and space limitations.
| Joint | Role | Recommended Models, Common Options |
|---|---|---|
| Shoulder joint | High-torque output core, carries the full arm load | AKH70-16 V1.0 KV41 / AK60-39 V3.0 KV80 |
| Elbow joint | Dynamic control and force transition | AKH70-16 KV41 / AK10-9 V2.0 KV60 |
| Wrist joint | Fine end-effector motion execution | AK45-36 / GL40 KV70 |
The key to choosing joint motors for humanoid robots is never about selecting the strongest option. It is about giving each joint the power configuration that fits its job. The shoulder must hold the load. The elbow must connect the motion. The wrist must handle the fine work. Only then can the whole arm move naturally and steadily, closer to a truly usable robot.
