
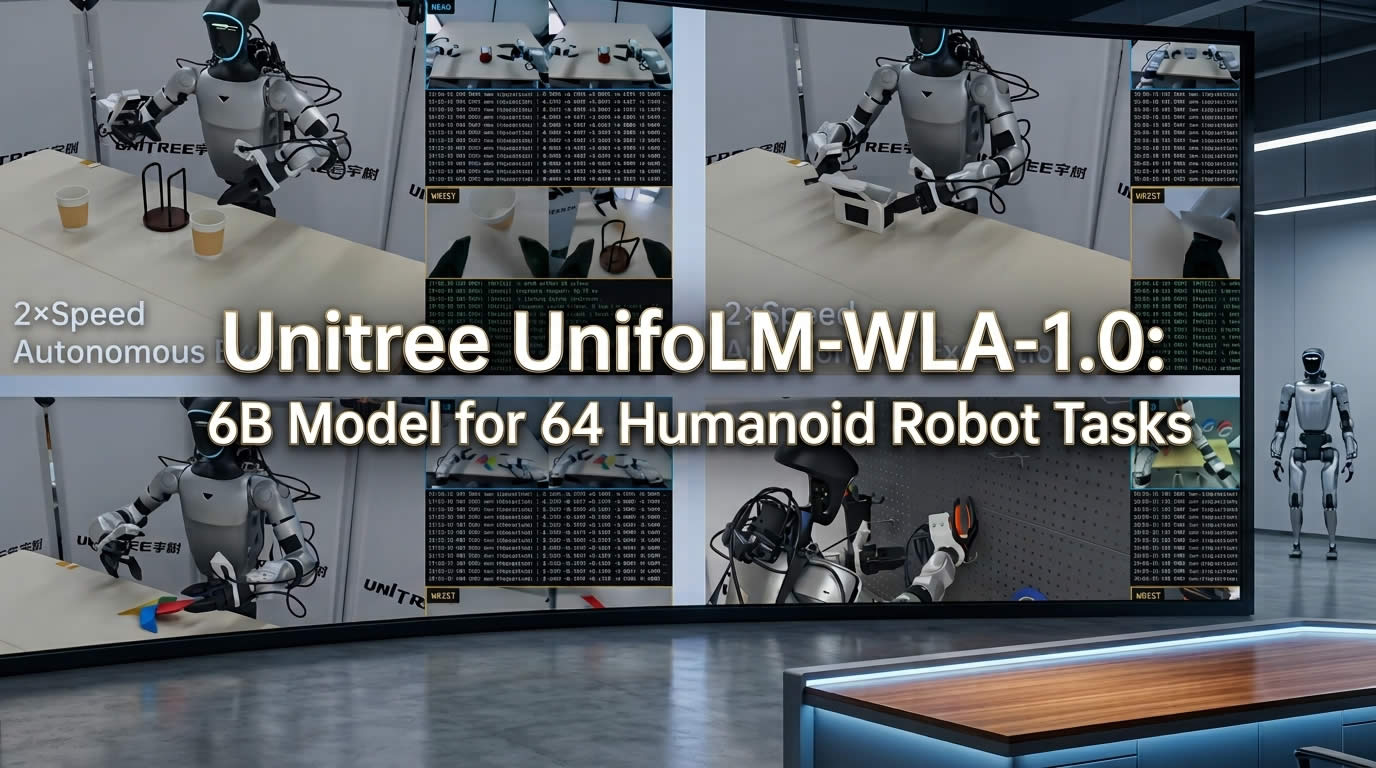
Unitree has published new details about UnifoLM-WLA-1.0, its latest general-purpose humanoid robot foundation model. According to the company, the model brings fine-grained tabletop manipulation and whole-body mobile manipulation into one system, using a unified action space to handle different end effectors. Unitree’s aim is to use one model for the full chain from perception and interaction decisions to action generation.
The model has 6 billion parameters. Unitree says it was trained on about 2,500 hours of high-quality real-robot data. The company’s real-robot tests cover 64 tasks: 10 whole-body manipulation tasks and 54 tabletop tasks. It supports parallel grippers and two types of dexterous hands.
For robot developers, the 64-task number may not be the most important part. The bigger question is whether the model can keep working across different robot embodiments and end effectors, and how well it generalizes to tasks it was not trained on. There is no external validation yet. Unitree has launched a project page and says it will release the model, code, and datasets. But the Code, Models, and Datasets pages still say “Coming soon.” The weights and datasets are not available for download.
64 tasks, but the hard part is coordination
Unitree lists tasks such as taking out trash, putting clothes in a washing machine, organizing shoes, cleaning bathrooms and kitchens, making beds, picking vegetables, tidying sofas, folding towels and clothes, putting away plates, and charging batteries. Ten are whole-body manipulation; 54 are tabletop.
The difference is not just workspace size. Tabletop tasks can often be done from a relatively fixed position, with the robot mainly controlling its arms, hands, and end effectors. In a kitchen, bathroom, or bedroom, the robot first has to change its position and posture, then bring both arms into the right workspace. Tasks like making a bed or tidying a sofa require the hands and body to move together.
Unitree’s approach is to have one model handle both types of action instead of building separate models for tabletop and whole-body manipulation. The model is also not tied to a single gripper. Unitree says UnifoLM-WLA-1.0 works with parallel grippers and two types of dexterous hands.
One action space for hands, arms, and lower body
To control a humanoid’s whole body with one model, the first problem is how to represent actions. Unitree splits actions into three parts: end-effector pose, end-effector joints, and lower-body joints. It then uses residual vector quantization, or RVQ, to turn continuous actions into discrete tokens. Tokens from different body parts are aligned at shared time steps and fed into the model together, so it can learn how the hands, end effectors, and lower body work together.
The result is a discrete action representation that the model can learn and predict in a unified way. The point is not a single action, but coordination between actions. Walking to a washing machine, for example, is not simply a “move” action followed by a “grab” action. The body has to reach the right position, the arms have to adjust, and the hands have to operate based on the target object. Putting these actions on the same timeline lets the model learn how they relate to each other.
Before acting, the robot has to know what will change
Another design choice in UnifoLM-WLA-1.0 is that it does not stop at understanding the current image. If the robot is about to pick up a plate, it needs more than “there is a plate here.” It also needs to know how the scene will change after the plate is removed, how a towel will deform when folded, and which parts of the scene will actually change when an object is pushed. Unitree calls these areas Dynamic Regions.
The method uses optical flow to extract changing regions from pairs of video frames, then uses a vector quantized variational autoencoder (VQ-VAE) to compress continuous changes into fixed-length discrete tokens. The model can then predict future regions of change based on the current image, task description, or action conditions. Unitree calls this interaction-centric world modeling. The idea is to predict how the scene will change when the robot interacts with it, not just describe the current frame.
UnifoLM-ER-Flow links vision and action
In this framework, Unitree puts visual, language, dynamic-region tokens, and action tokens into a unified multimodal model called UnifoLM-ER-Flow. UnifoLM-WLA-1.0 adds an MMDiT Action Expert module on top to generate continuous robot actions. Unitree says the system combines embodied reasoning, future dynamic-region prediction, and discrete action learning in one multimodal framework.
The pipeline has three connected parts: understand space and the task, predict how interaction may change things, then generate robot actions.
2,500 hours of real-robot data
UnifoLM-WLA-1.0 was trained on about 2,500 hours of real-robot data. Unitree says the data comes from its own open-source datasets and public resources such as HIW-500, and covers multiple robot embodiments and operating environments. The model also uses a unified action space and cross-embodiment transfer priors.
That distinction matters when calling a robot model a “foundation model.” A model that only completes a set of tasks on a fixed robot, fixed end effector, and fixed scene is closer to a specialized control model. A foundation model should retain some ability to transfer when the hardware or task changes. Unitree has included different robot embodiments, two types of dexterous hands, and parallel grippers in its training and testing framework. But the public information is not enough to judge how well it transfers to third-party robots. How well it transfers to third-party hardware will be easier to judge once the release is available.
5 million embodied reasoning samples from UnifoLM-ER-1-4B
Behind the action model is a separate embodied reasoning model. Unitree’s UnifoLM-ER-1-4B is based on Qwen3-VL-4B and uses more than 5 million embodied reasoning samples. The data covers image point prediction, object detection, multi-image reasoning, 2D trajectory prediction, 3D object detection, and multi-image spatial question answering, and is trained jointly with general image-text data.
This model is mainly about spatial understanding before action. The robot needs to know where objects are, how they relate to each other, where the target location is, and which parts of the scene its actions may affect. That information gives the action model the spatial context it needs.
Unitree Reports Top Scores in Seven Benchmarks
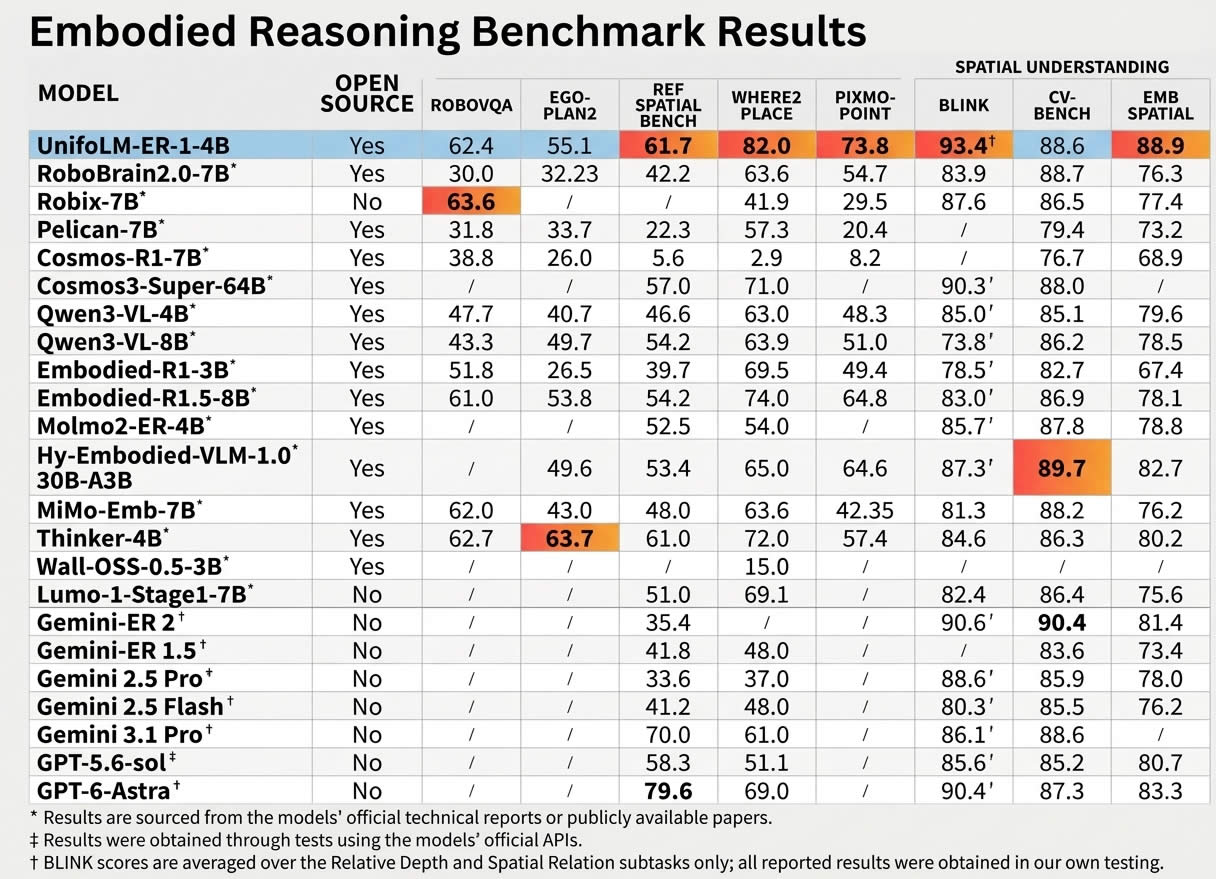
Unitree published results on 16 multimodal perception and understanding benchmarks. UnifoLM-ER-1-4B scored highest among evaluated open-source models on seven: RefSpatial-Bench, Where2Place, PixMo-Point, BLINK, EmbSpatial, RoboSpatial, and VSR.
The published scores include:
- Where2Place: 82.0
- PixMo-Point: 73.8
- EmbSpatial: 88.9
- RoboSpatial: 73.1
Unitree also shared comparisons with some closed-source models. In tests both systems took, UnifoLM-ER-1-4B scored 82.0 on Where2Place, 13 points higher than GPT-6 Astra; 93.4 on BLINK, 3 points higher; 88.6 on CV-Bench, 1.3 points higher; and 88.9 on EmbSpatial, 5.6 points higher.
Those numbers need context. They are benchmark results published by Unitree, not rankings from an independent testing organization. The available material does not include third-party reproductions. The benchmark results do not, on their own, show that UnifoLM-WLA-1.0 outperforms other models on real robot tasks. The stronger test will be real-robot success rates, failure types, and whether the model can transfer to other robots without targeted retraining.
Open-source plan announced, but weights are not here yet
The UnifoLM-WLA-1.0 project page is live, and Unitree says it will release the model, code, and datasets. As of now, the Code, Models, and Datasets sections on the site are still marked “Coming soon.” The source code, model weights, and datasets have not been officially released for download.
That means developers can read about the architecture, task coverage, and benchmark results, but they cannot yet download the full open-source package and reproduce the work independently. The real test will come when outside researchers can run the model on tasks and robot platforms beyond Unitree’s published evaluation.
Project page: https://unigen-x.github.io/unifolm-wla.github.io/
